英伟达GR00T 2:每项任务1次示范50项平均成功率71%,5次达95%
英伟达11月9日在美国奥斯汀CoRL机器人学习大会期间发布博客称,基于Cosmos的新一代世界动作模型GR00T 2在每项任务仅1次示范的条件下,50项任务平均成功率达71%,5次示范时升至95%;在没有针对性示范时也至少完成过50项中的40项。
英伟达研究页面显示,其预训练数据包含402,730小时第一视角人类视频,其中10万小时已开源,约为英伟达公布的GR00T N1.7所用20,854小时的19倍。英伟达同时推出Isaac Lab 3.0,称结合Newton物理引擎训练吞吐量最高提升2.5倍。
英伟达于11月9日在美国奥斯汀举行的机器人学习大会(CoRL)上发布GR00T 2。公司博客称,这是一款基于Cosmos平台的开放世界动作模型。英伟达表示,在每项任务只提供1次示范的情况下,模型在50项评测任务中的平均成功率为71%,示范增至5次时达到95%;在完全没有针对性示范时,也至少成功完成过其中40项。公司称,该模型可以从人类示范中学习,并在没有机器人示范的情况下把技能迁移到不同形态的机器人上。
训练数据是这次发布的重点。博客称GR00T 2使用了机器人数据以及英伟达开源的10万小时第一视角人类视频。这10万小时是公开部分。英伟达GR00T 2研究页面显示,预训练数据包括402,730小时人们工作时的第一视角视频、23,500小时机器人遥操作数据和10,184小时手持夹爪示范,其中10万小时人类视频已在Hugging Face公开。英伟达GR00T的GitHub仓库仍把GR00T N1.7列为最新公开版本,并写明N1.7预训练使用了2万小时EgoScale人类视频,英伟达在Hugging Face发布的文章给出的精确数字为20,854小时。按MEKAWIRE计算(402,730÷20,854),GR00T 2预训练所用人类视频约为N1.7的19倍。英伟达称GR00T 2在RoboCasa365、RoboLab、RoboDojo和MolmoSpaces四个榜单的VLA和世界动作模型类别中均位列前三。博客显示,Nexuni正在用它测试衣物处理,富士康将其用于服务器制造自动化,西门子正在评估工业场景应用。
Isaac Lab 3.0转向Newton
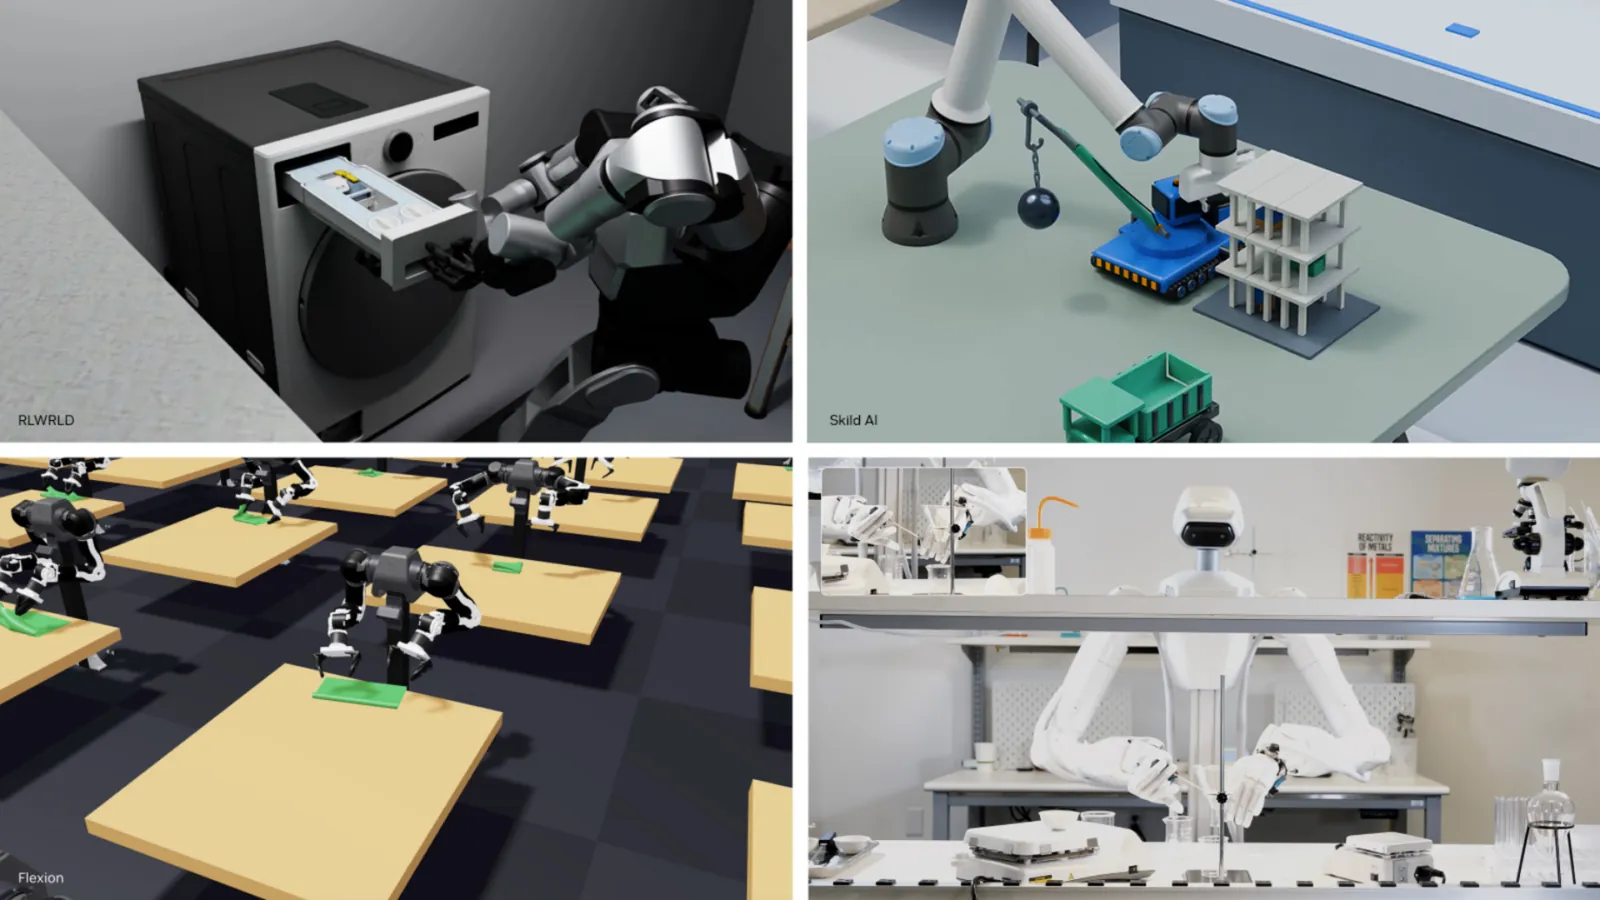
开源机器人学习框架Isaac Lab 3.0支持由智能体搭建训练环境,可在PhysX和Newton物理求解器之间切换,并为GR00T等基础模型提供新的强化学习后训练库。结合Newton后,它可以模拟线缆、布料等可变形物体和多关节灵巧手。英伟达称,在基于视觉的灵巧操作基准中,使用Newton的Isaac Lab 3.0训练吞吐量最高可达使用PhysX的2.3版的2.5倍。Skild AI发布了基于Newton的刚体物理求解器STEEL,Flexion、FieldAI和RLWRLD也在英伟达点名的合作伙伴之列。
GR00T 2处于什么位置
- 英伟达GR00T N1.7
- 当前GitHub公开版
- 20,854小时(EgoScale)
- 有,30亿参数,英伟达开放模型许可
- README称性能与N1.6相当,RTX PRO 6000上约40Hz
- 英伟达GR00T 2
- 2026年11月9日
- 预训练402,730小时(10万小时开源)及机器人数据
- 截至11月14日公开仓库未见
- 四个榜单前三
- Runway Praxis-1
- 2026年9月30日(11月11日开放权重)
- 未披露
- 有,270亿参数,Apache 2.0
- RoboLab-120为46.2%
来源:英伟达博客(11月9日)、英伟达GR00T 2研究页面、英伟达Isaac-GR00T GitHub README(11月14日查看)、Runway发布(9月30日和11月11日)。人类视频倍数为MEKAWIRE计算。
截至 2026年11月14日
各家基准说法无法直接比较:Runway在11月11日给出了Praxis-1在RoboLab-120上的单一分数,而英伟达只给出四个榜单的排名区间。
MEKAWIRE 分析
就在OpenAI把机器人团队并入通用研究的同一周,英伟达加码以人类视频为主训练的机器人专用世界动作模型。两条路线不可能同时都是成本最低的那一条。
对商业用户最有意义的是从71%到95%的曲线:如果5次示范就能在真实任务中达到95%,工厂导入成本将大幅下降。对中国厂商而言,宇树、智元等硬件企业若接入GR00T生态,可以节省数据采集成本,但也会加深对英伟达软件栈的依赖。反方观点是,这50项任务及其条件由英伟达自行设定,而且截至MEKAWIRE 11月14日查看时,公开仓库中还没有模型权重。值得关注:带权重和许可证的GR00T 2模型卡、第三方榜单成绩,以及富士康或西门子是否公布实际产线应用。
- 每项任务1次示范,50项平均71%;5次示范95%(英伟达)
- 50项中40项至少成功一次
- 预训练402,730小时(10万小时开源),约为GR00T N1.7所用20,854小时的19倍(MEKAWIRE计算)
- RoboCasa365、RoboLab、RoboDojo、MolmoSpaces前三(英伟达)
- 训练吞吐量最高为2.3版的2.5倍
- Nexuni、富士康、西门子、MicroAGI
- 2026年11月9日,CoRL,奥斯汀
为何重要
NVIDIA reports 71% average success across 50 tasks with one demonstration per task and 95% with five, suggesting lower task-specific data requirements if results transfer to production. Completing 40 of 50 tasks at least once without task demonstrations indicates breadth but leaves repeatability unresolved. Named users are Nexuni, Foxconn, Siemens and MicroAGI, while deployment volumes and commercial terms are absent.
竞争对手分析
The supplied material lists Physical Intelligence as a direct rival to Skild AI in robot foundation models, and Skild AI builds a general-purpose model meant to run on many robot types. Runway released Praxis-1 with open weights on Nov 11 and is extending its world models into robot control, per the supplied company description. RLWRLD, Flexion and FieldAI are also building robot foundation or autonomy stacks, but the input does not position them against GR00T 2, and it provides no matched benchmark comparison with NVIDIA.
估值背景
NVIDIA is public, but the supplied material gives no market cap or valuation estimate, so no pricing assessment is possible here. For peer context only, Skild AI's $14B valuation is disclosed, with $1.7B total funding including a $1.4B Series C. Flexion's $50M and FieldAI's $405M are funding figures, and no valuation is supplied for either.
研究依据
The supplied NVIDIA papers are ChunkTrust, Magic-W0 and AlphaNIST, whose titles cover execution horizons, world-action modeling and assembly skills. RLWRLD lists PointWAM and PaceVLA, and Skild AI lists a sim-to-real humanoid locomotion paper. No results or direct links to GR00T 2's reported gains are supplied.
供应链影响
NVIDIA supplies Isaac, GR00T, Cosmos and Jetson Thor, giving it several points of participation in robot development. GR00T 2 pretraining uses 402,730 hours of egocentric human video, of which 100,000 hours are openly released, about 19 times the 20,854 hours NVIDIA gives for GR00T N1.7 (MEKAWIRE calculation). Hardware requirements, component suppliers and deployment costs are not specified.
后续看点
Watch for independent replication of the 71% and 95% success rates, including repeated trials of tasks completed without demonstrations. Production volumes and paid deployments among named users would clarify commercial adoption. Check whether Isaac Lab 3.0's claimed throughput of up to 2.5x versus Isaac Lab 2.3 with PhysX translates into lower training costs on comparable workloads.
分析师观点
If fewer demonstrations and faster simulation reduce development effort, NVIDIA's physical-AI stack could see broader adoption. The supplied evidence, which is NVIDIA's own reporting, supports technical progress, while revenue impact is unquantified. Repeatable production performance and deployment economics should drive any commercial assessment.
值得追问的问题
How many trials underpin each success rate, and what hardware, task selection and evaluation conditions were used? Which named users have paid production deployments, and what are their intervention rates, training costs and deployment volumes?