RoboParty opens up its RP1 humanoid down to the actuators, offering a 1.3-metre research robot with 24 or 30 joints
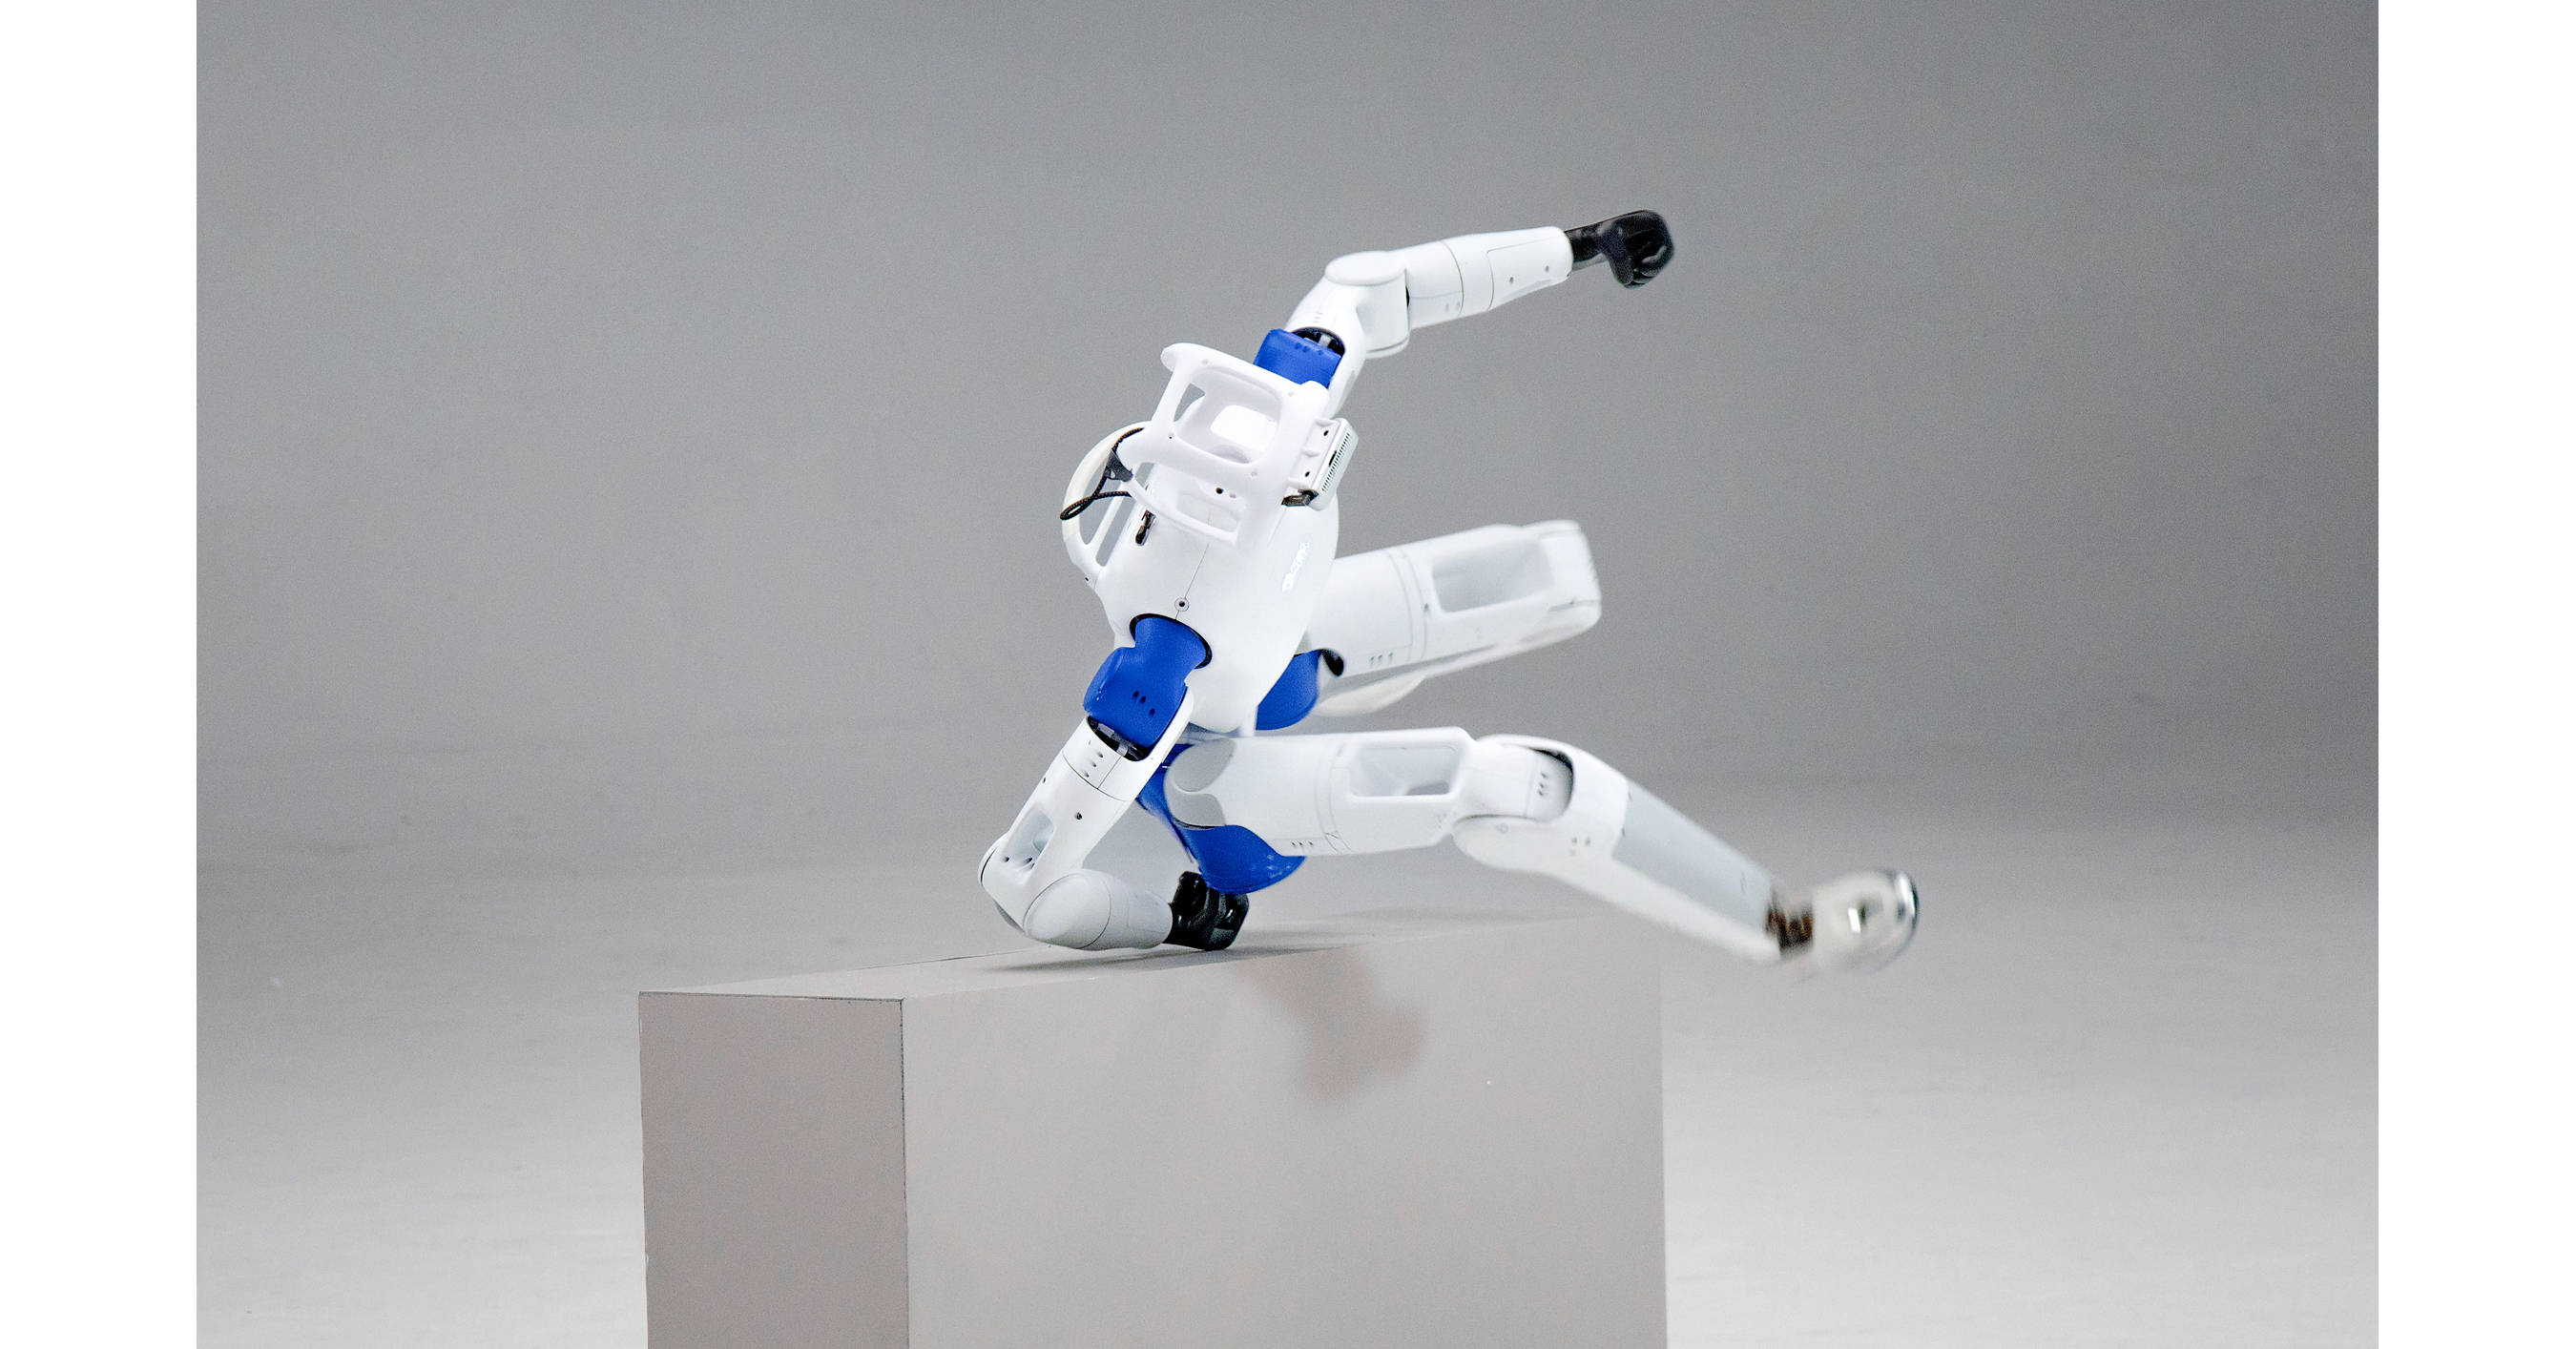
Shanghai-datelined RoboParty said in a press release on Oct 15 that it has launched RP1 (ROBOTO 01), a humanoid it describes as open source across the full stack: the robot body design, technical resources for its in-house ROMOMO joint actuator modules, low-level drivers and control algorithms, firmware, simulation resources, SDKs and robot-learning tools.
The standard RP1 stands about 1.3 metres tall with 24 actuated degrees of freedom; a Pro version has 30, including a two-axis neck and two seven-axis arms, with dexterous hands not counted. RoboParty says the robot already walks continuously, recovers from pushes, gets up after a fall and tracks human motion, and ships with whole-body control, VR teleoperation, data-collection and motion-retargeting workflows tied to its PartyOS system, UFO unsupervised reinforcement-learning framework and MimicLite imitation tool.
Founder Yi Huang said embodied AI should not be defined by a handful of closed systems. The release gives no price, shipping date or licence terms; the robot was first shown at IROS earlier this month.
Open hardware matters because most lab work still runs on closed commercial platforms: the last humanoid paper MEKAWIRE briefed, Cornell and Multiply Labs' KinoGen, was tested on a Unitree G1.